Elementary
Plastic / 3DP body
Gripper / Laser / Pen heads
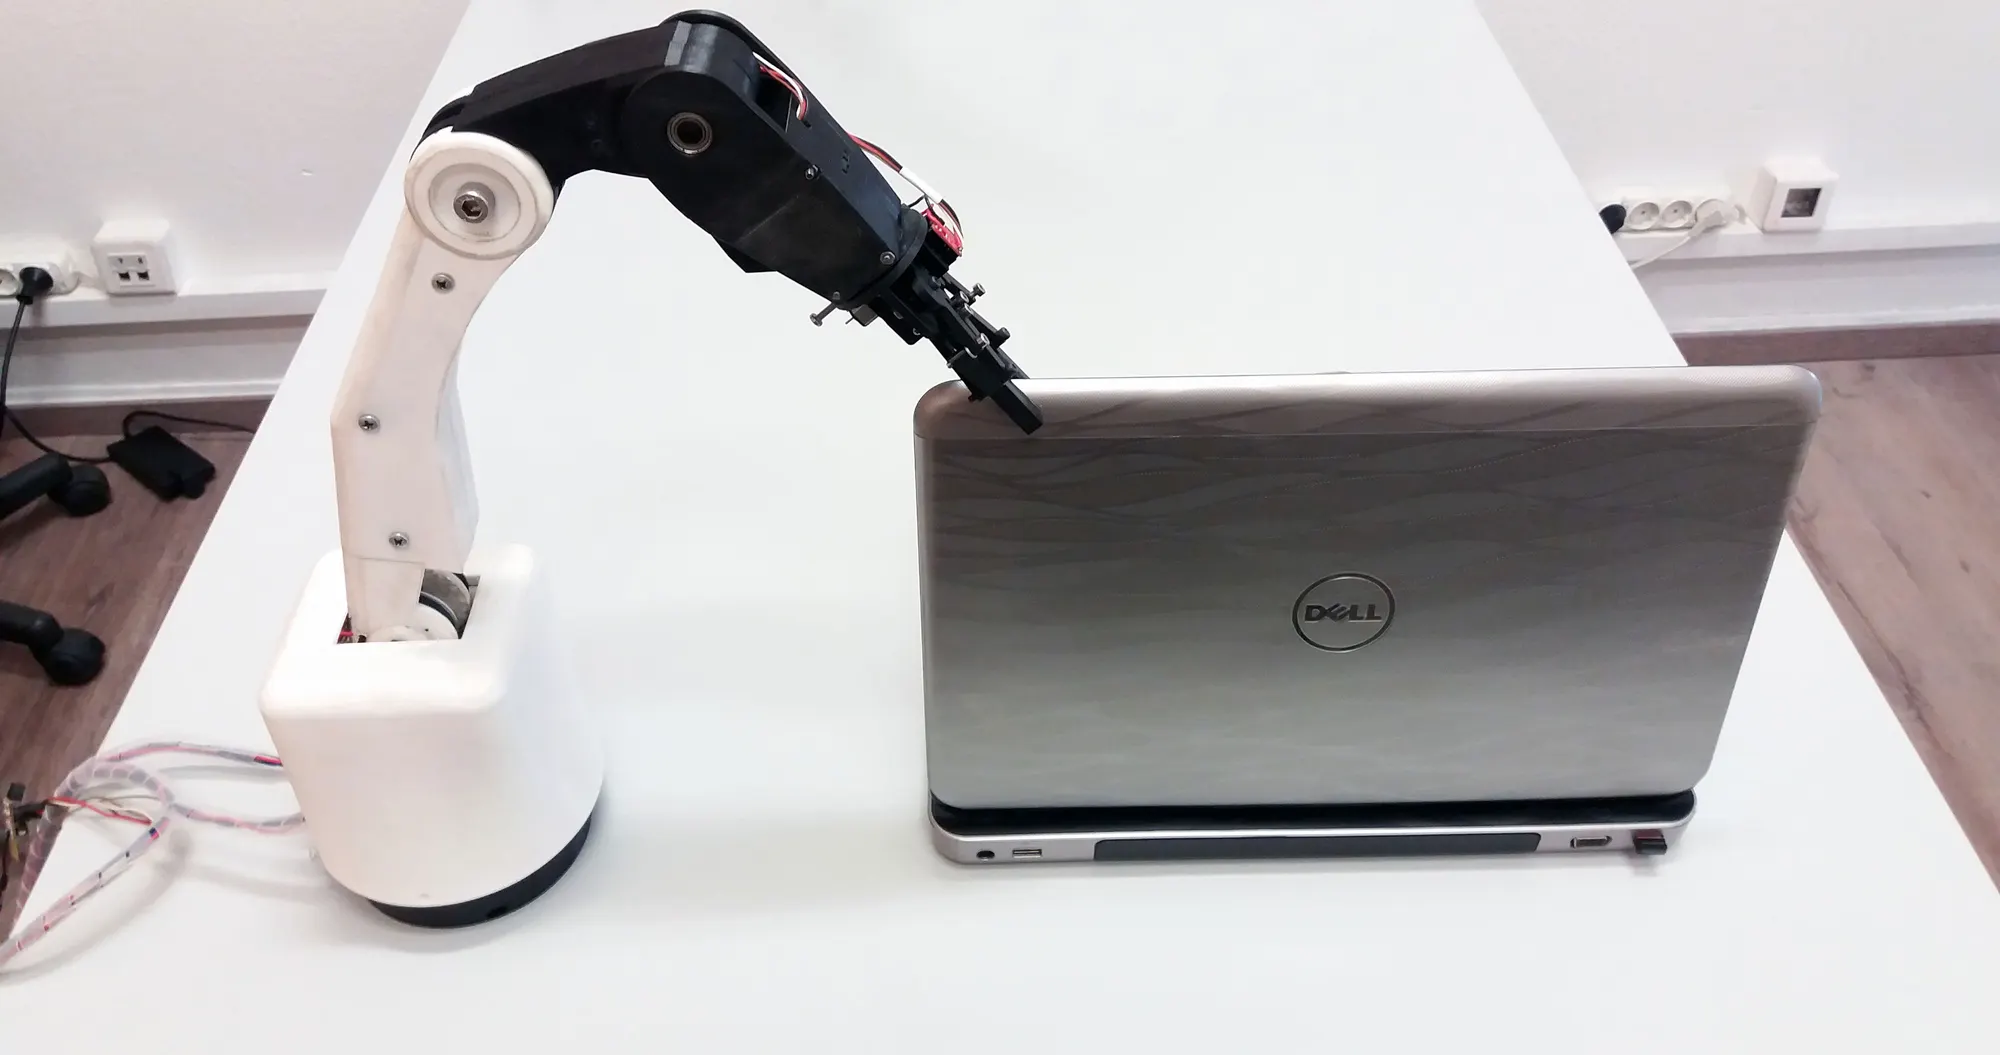
6-DOF ROBOTIC ARM · 2013-2017
Our vision is to provide to every layperson, scientist, designer, enthusiast, student a low-cost, high-precision, portable robotic arm, with changing head tools, capable of performing digitally supported processes such as 3D printing, milling, drawing, gripping, laser cutting.
HUM[erus] can offer the qualities of today’s desktop box-shaped 3D printers, miniature milling machines or laser engravers yet enabling for even more features and functionalities. Our robotic arm measures approximately 10x10x40 cm and has a considerably big corresponding workspace volume [40x40x30 cm] in relation to its small size. It is a 6DOF robotic arm that is equipped with our proprietary technology 01TM Supermodified Controller for DC motor, each node has 15bit encoders and a proprietary firmware that is able to correct structural backlash. Internally each node is operated by a clever timing pulley-belt transmission. The positional repeatability at the end-tip is an astonishing 0.5mm while the maximum load is 600gr (Alu-body).
The product line we envision is the following:
Plastic / 3DP body
Gripper / Laser / Pen heads
Aluminum body
Gripper / Laser / Pen / 3DP head
Alu / Carbon
Gripper / Laser / Pen / 3DP / engraving head
Elementary and Special are robotic arms already developed by our teams. The competitive advantage is its portability, its unmatched accuracy as well as its low price. Existing mini robotic arms cost ten times the price of HUM[erus], even without being portable. Finally, thanks to the implementation of our inhouse high resolution motors and controllers that drive its hardware, HUM[erus] can achieve accuracy and operational values of industrial excellence.
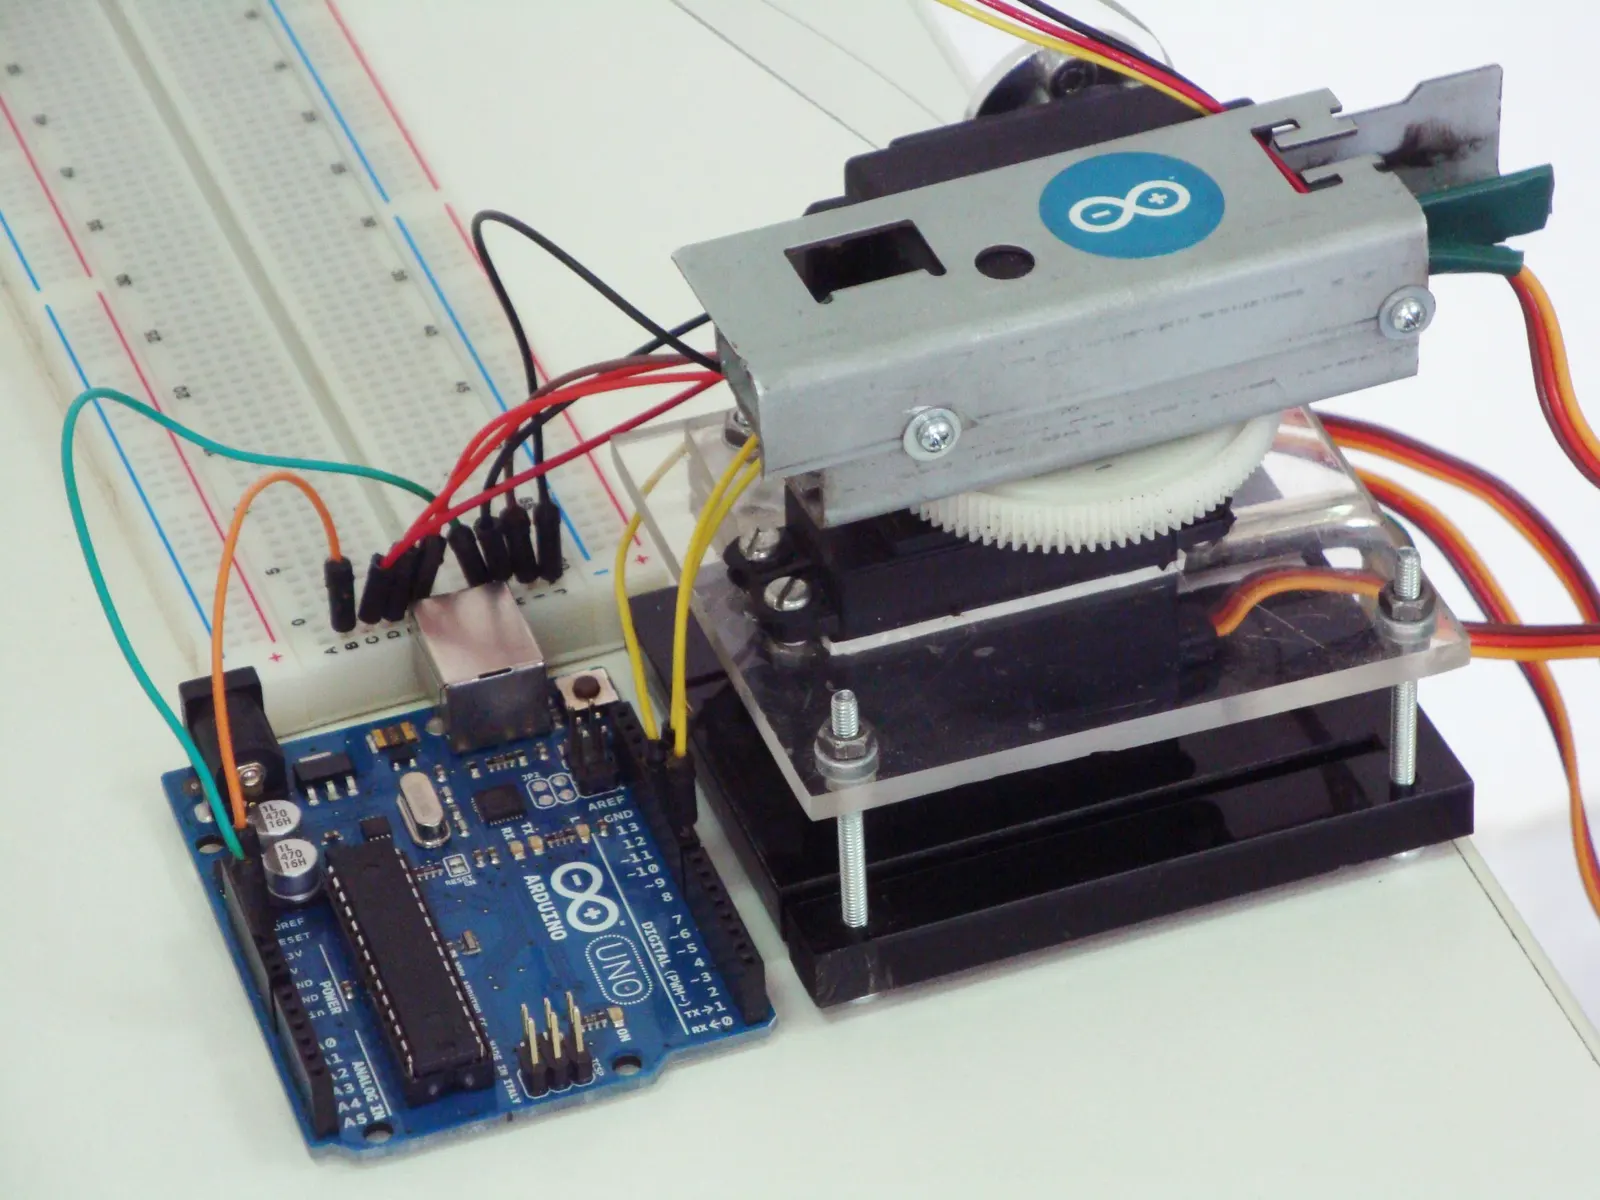 01
A folding plexiglass arm with four servo motors, chosen for low cost, small size and high torque.
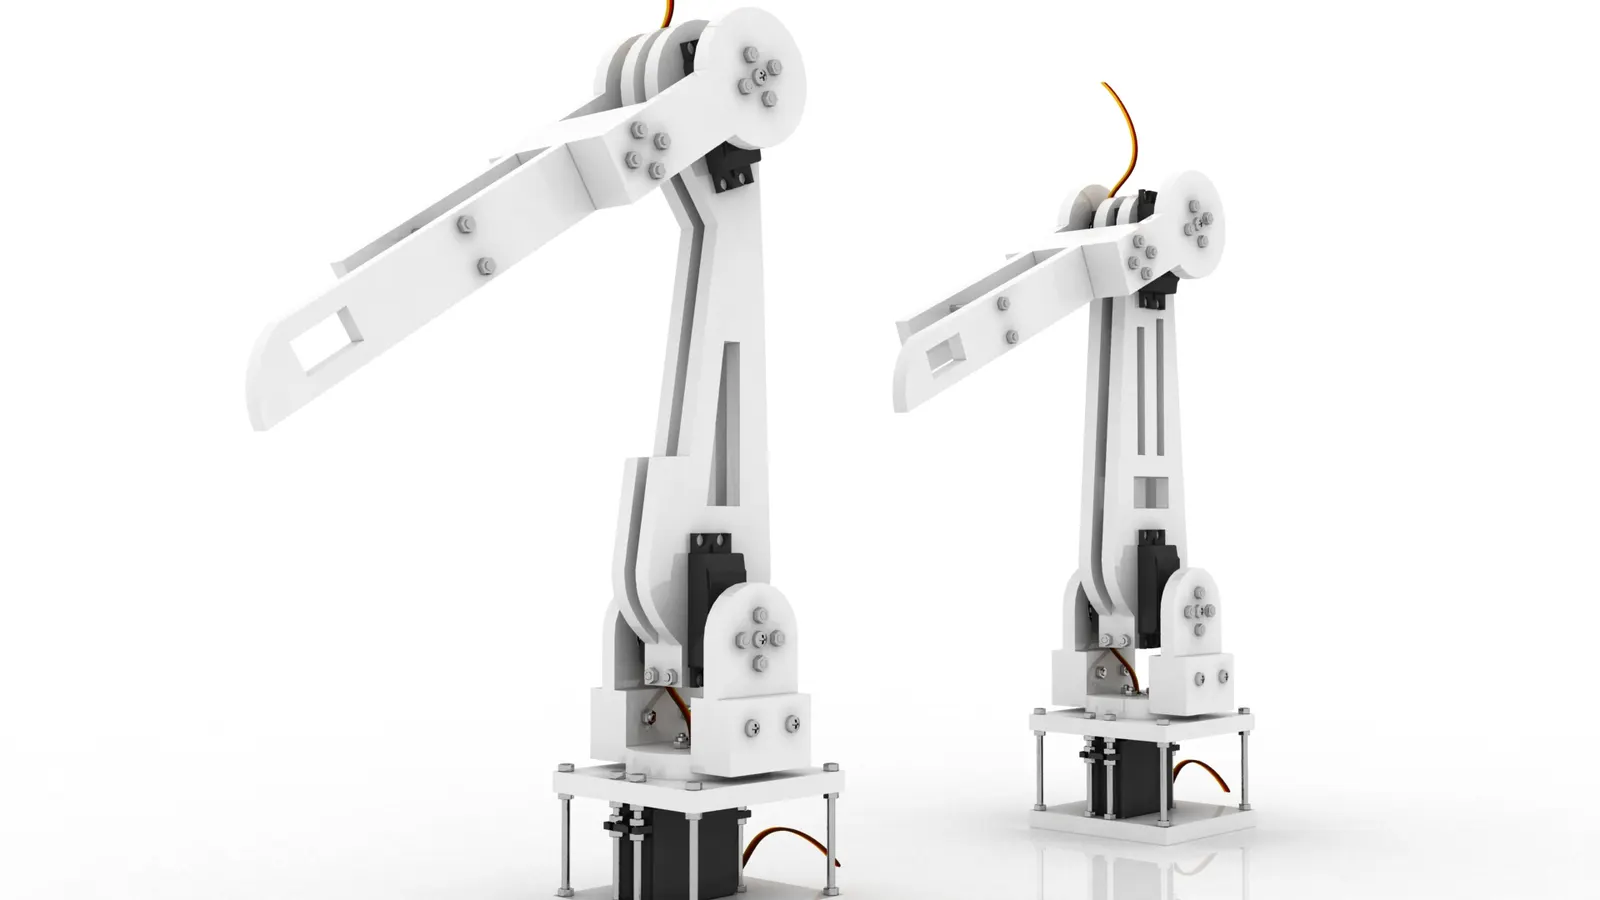 02
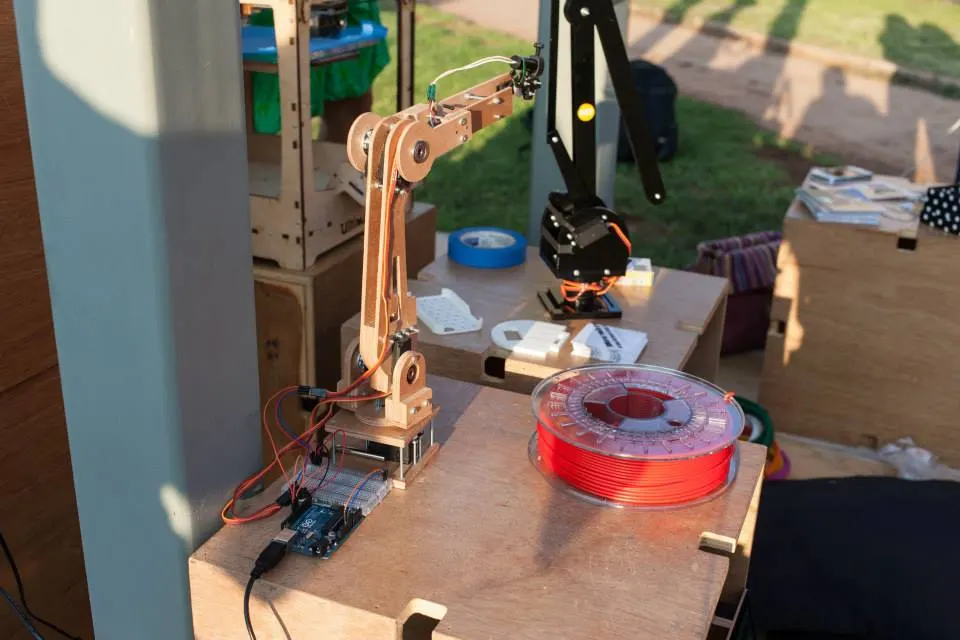
Arduino-based arm, first 3D-modelled design.
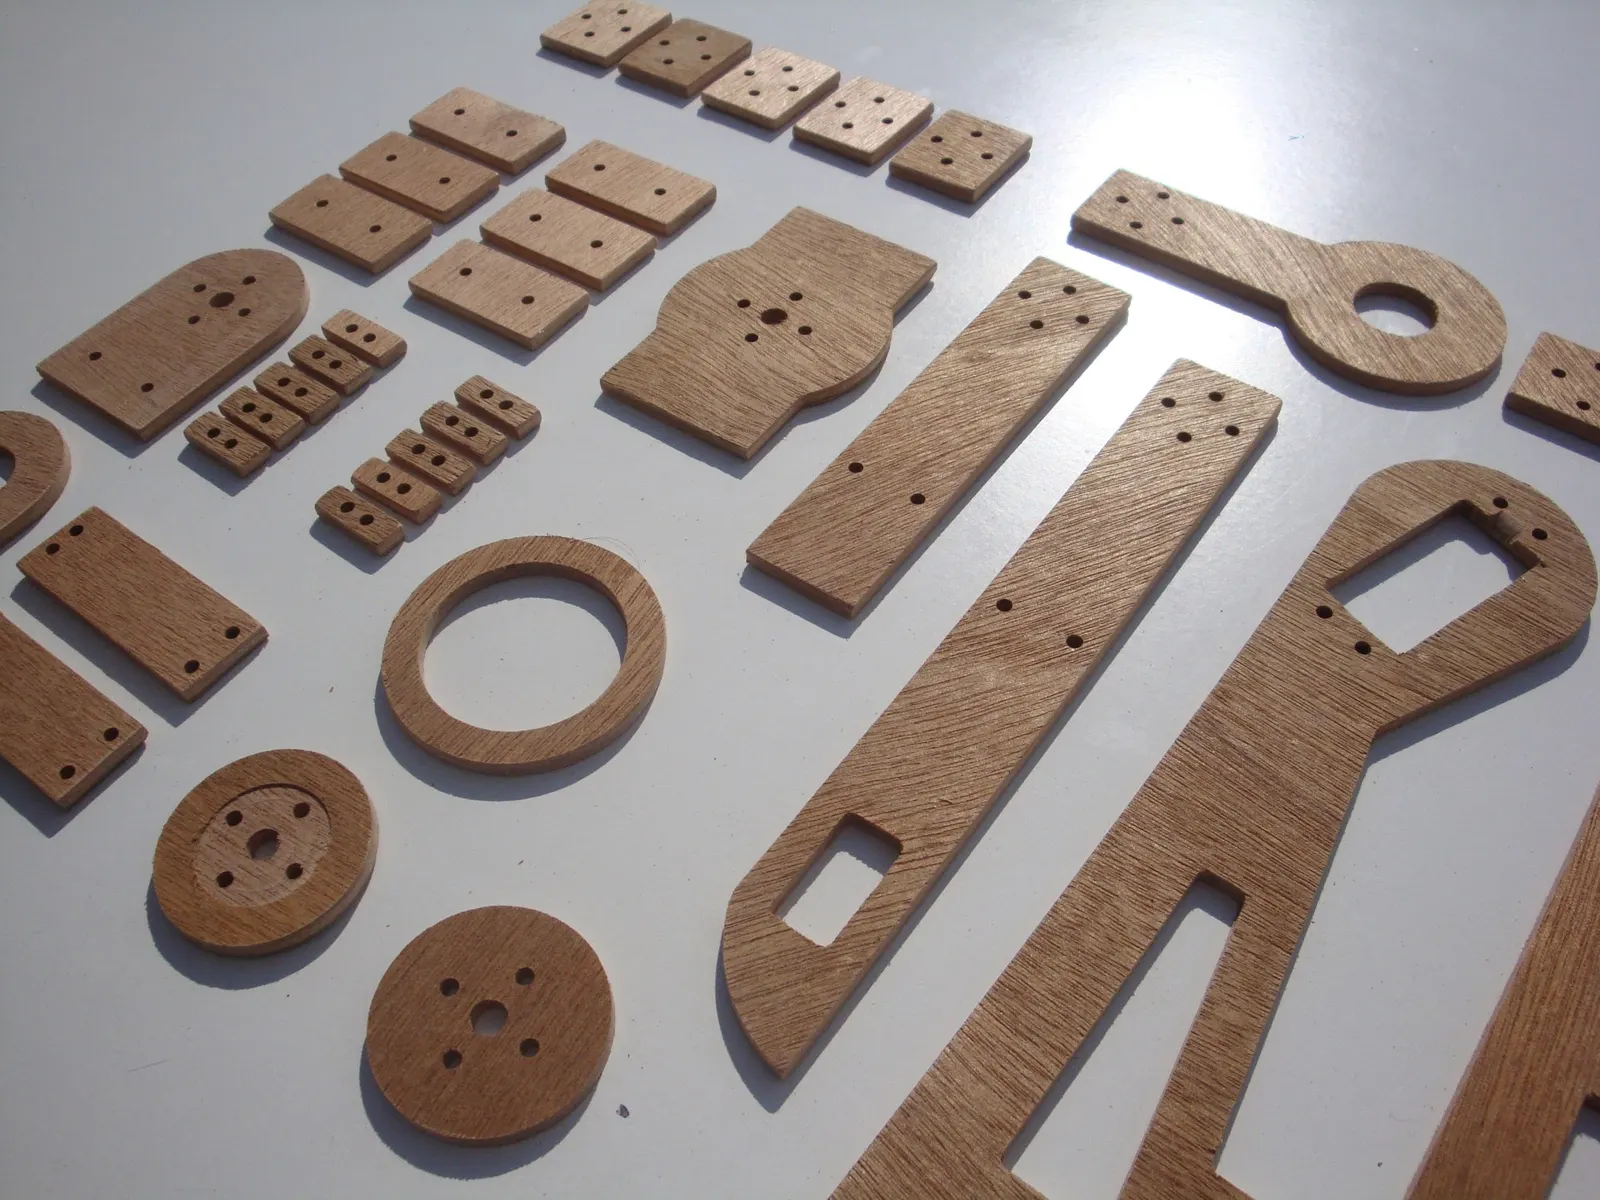 03
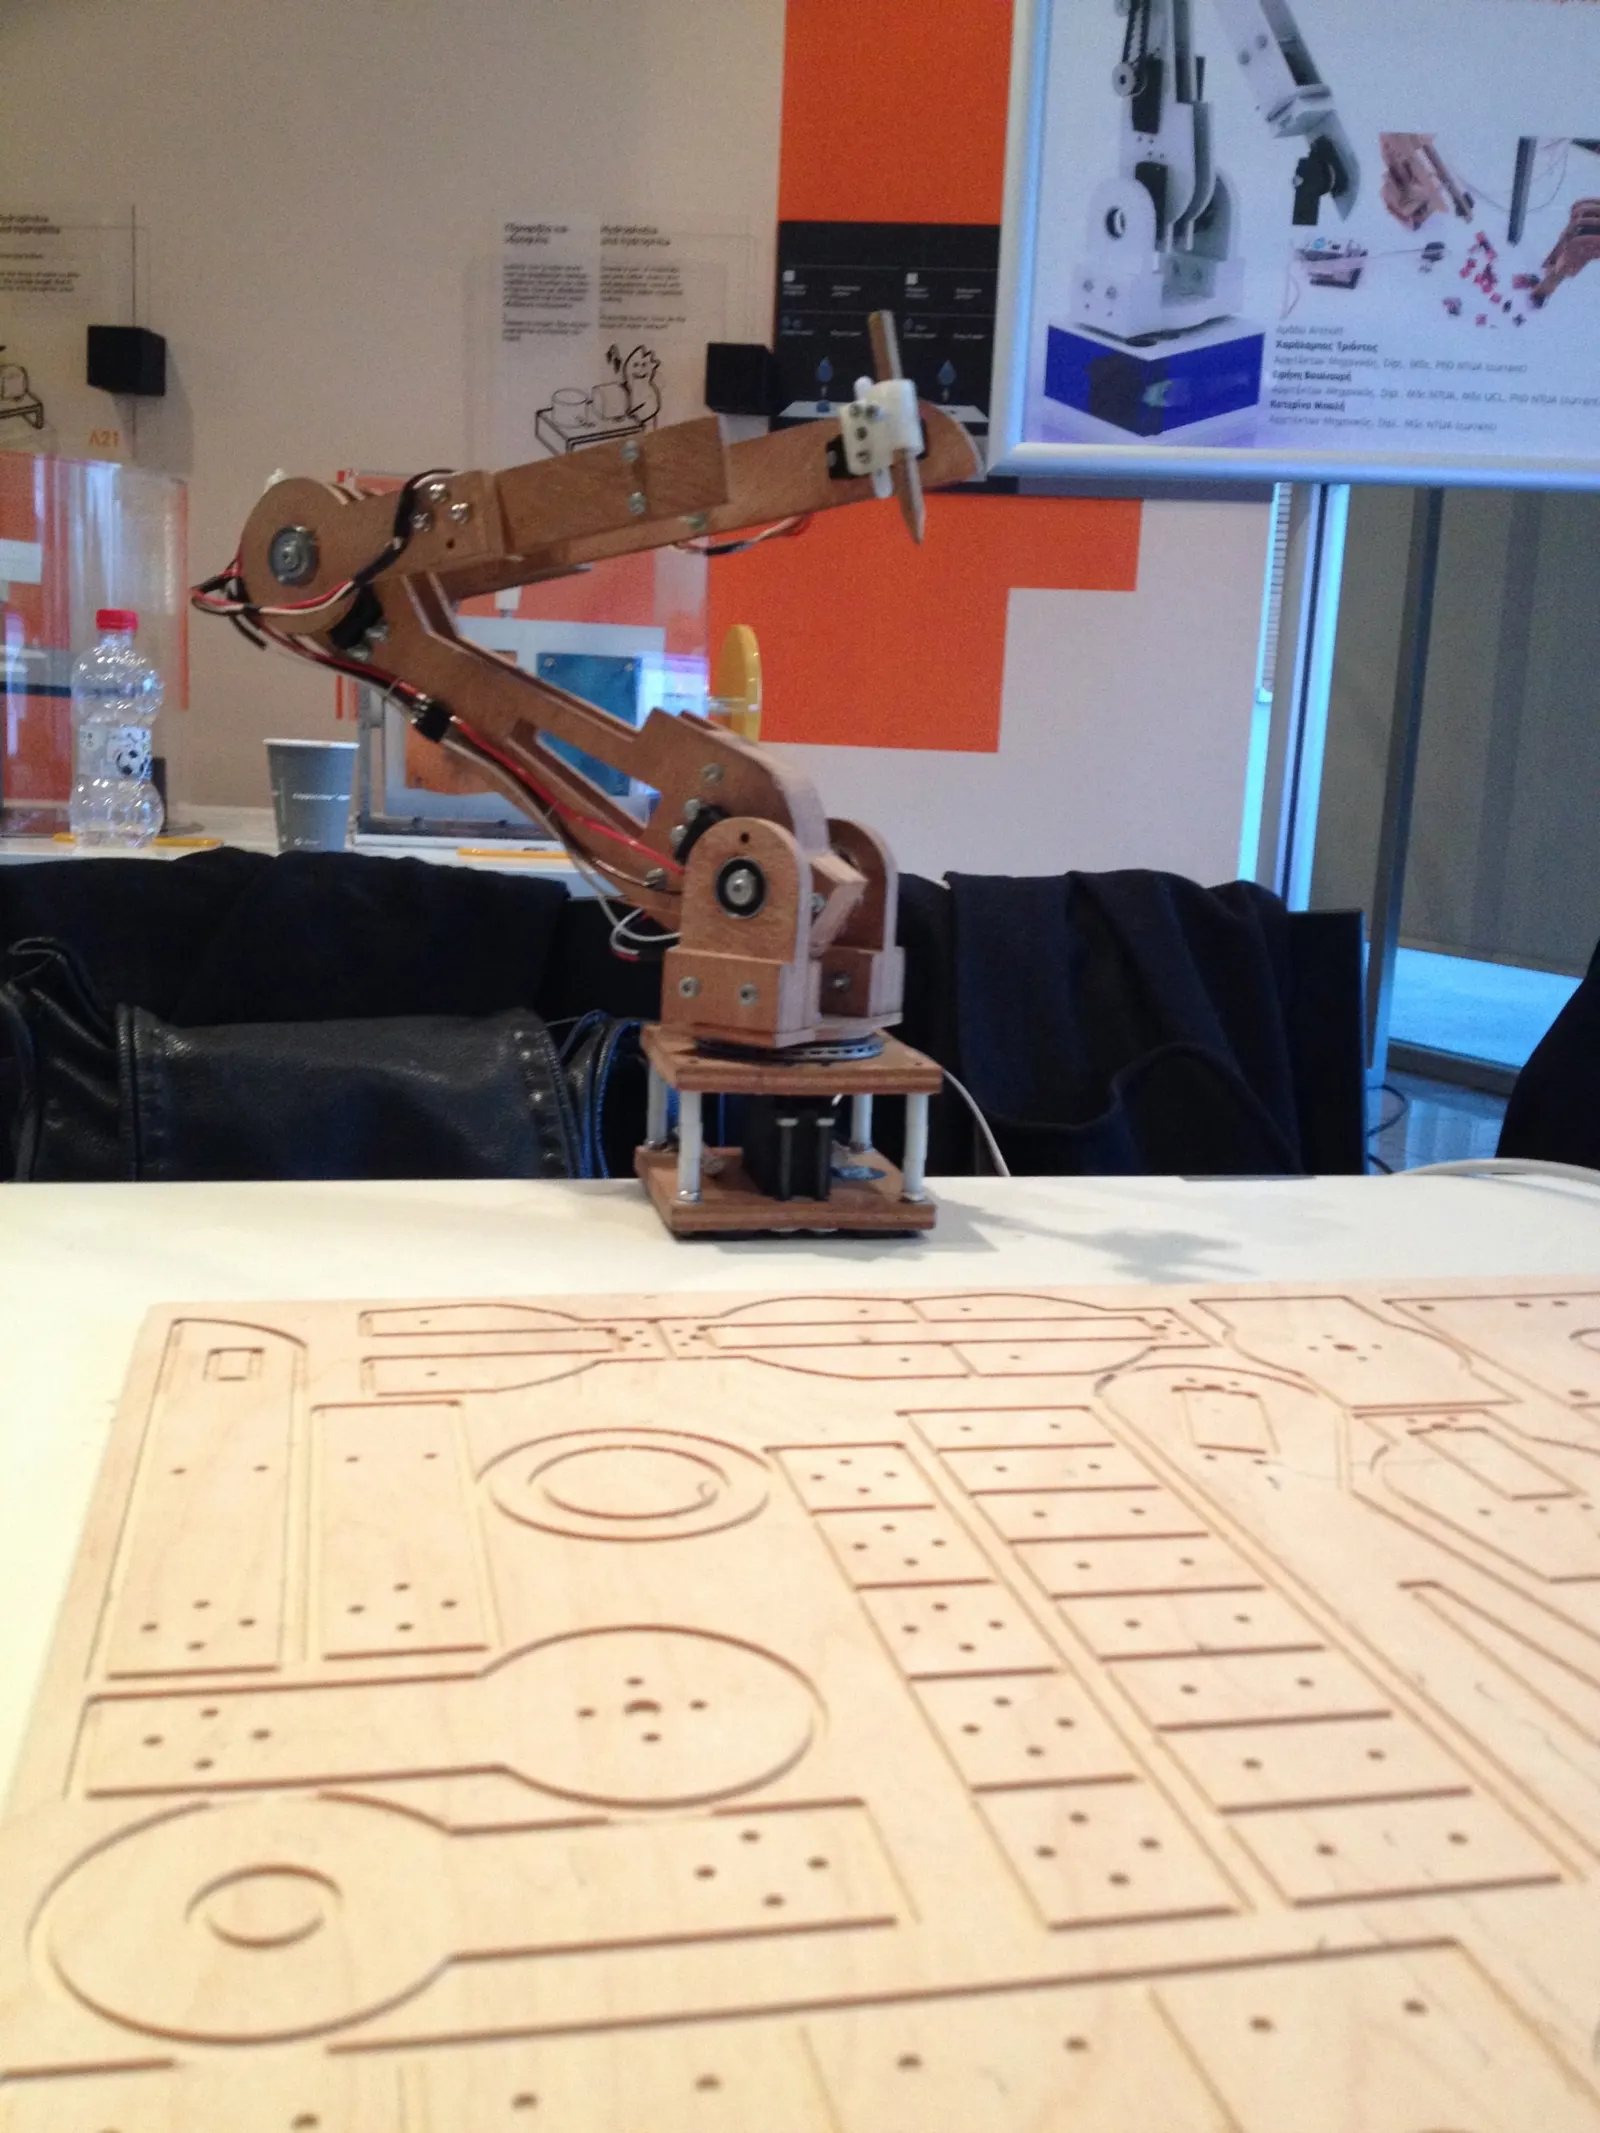
Flat-pack wooden kit: digital fabrication, open hardware, low cost, portable.
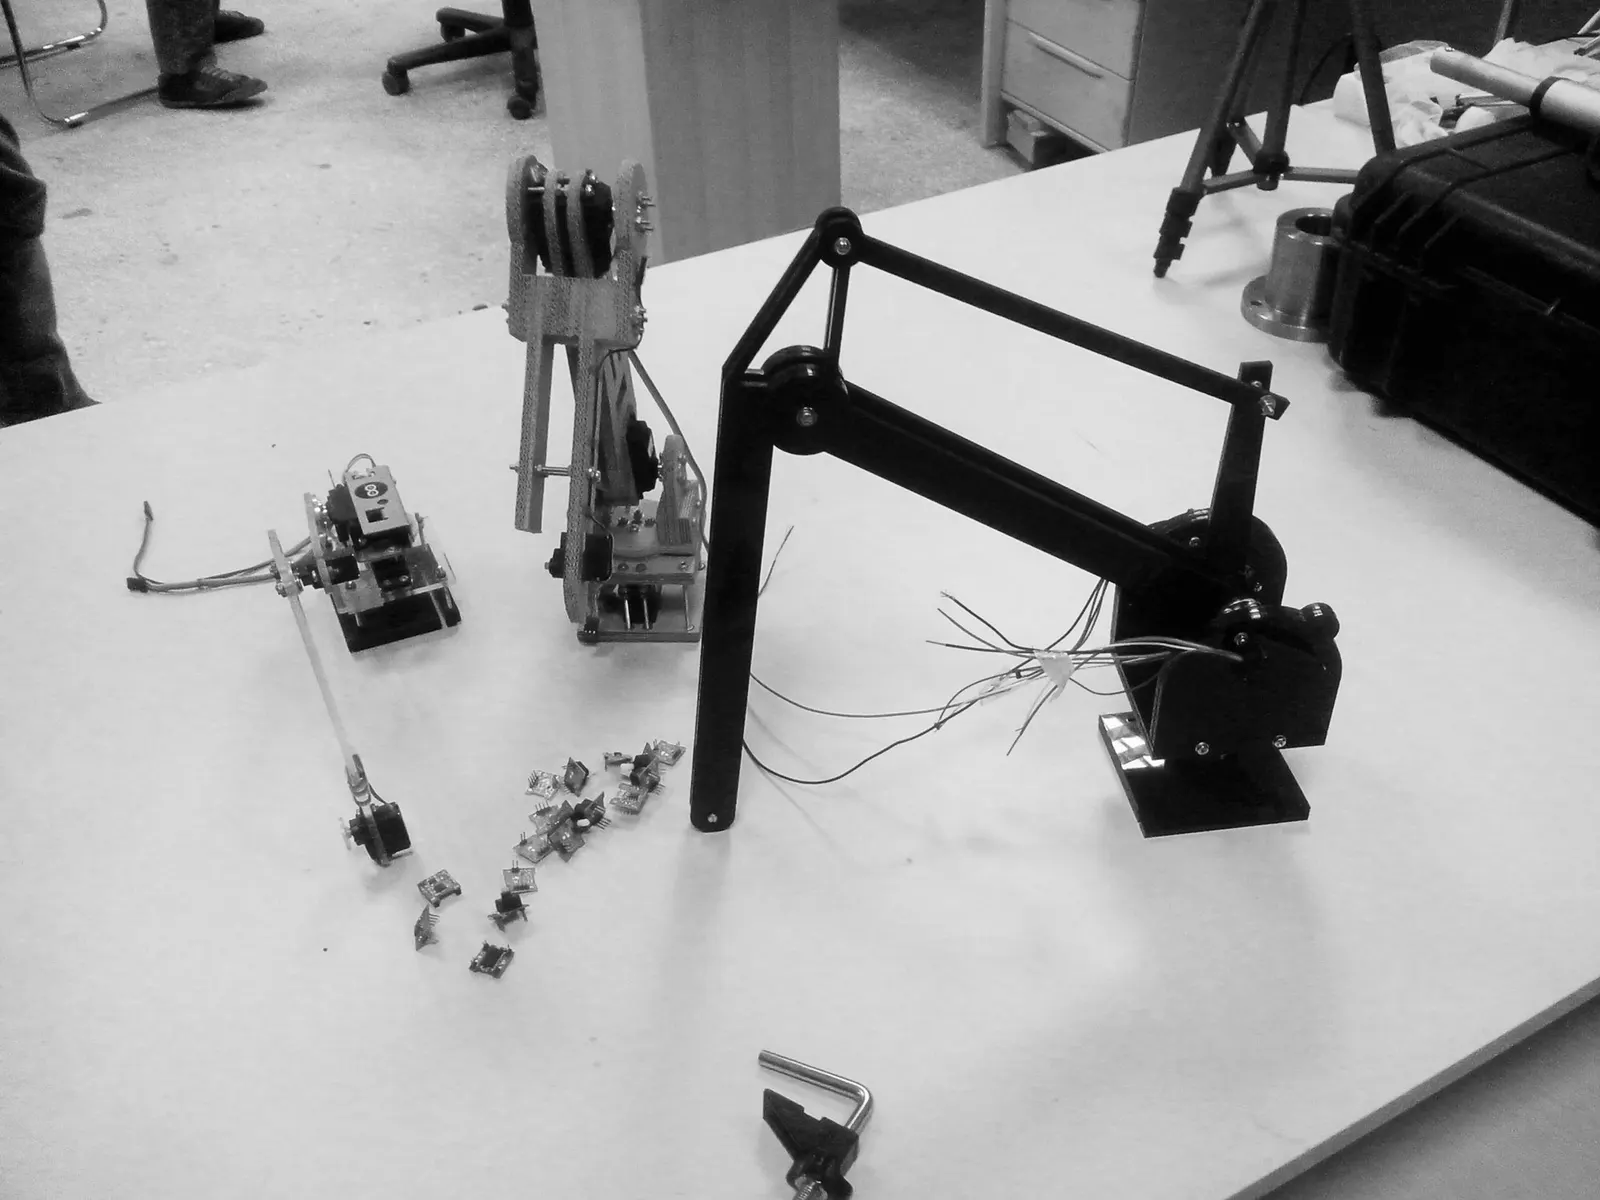 04
Black arm, shown at Researchers’ Night 2014.
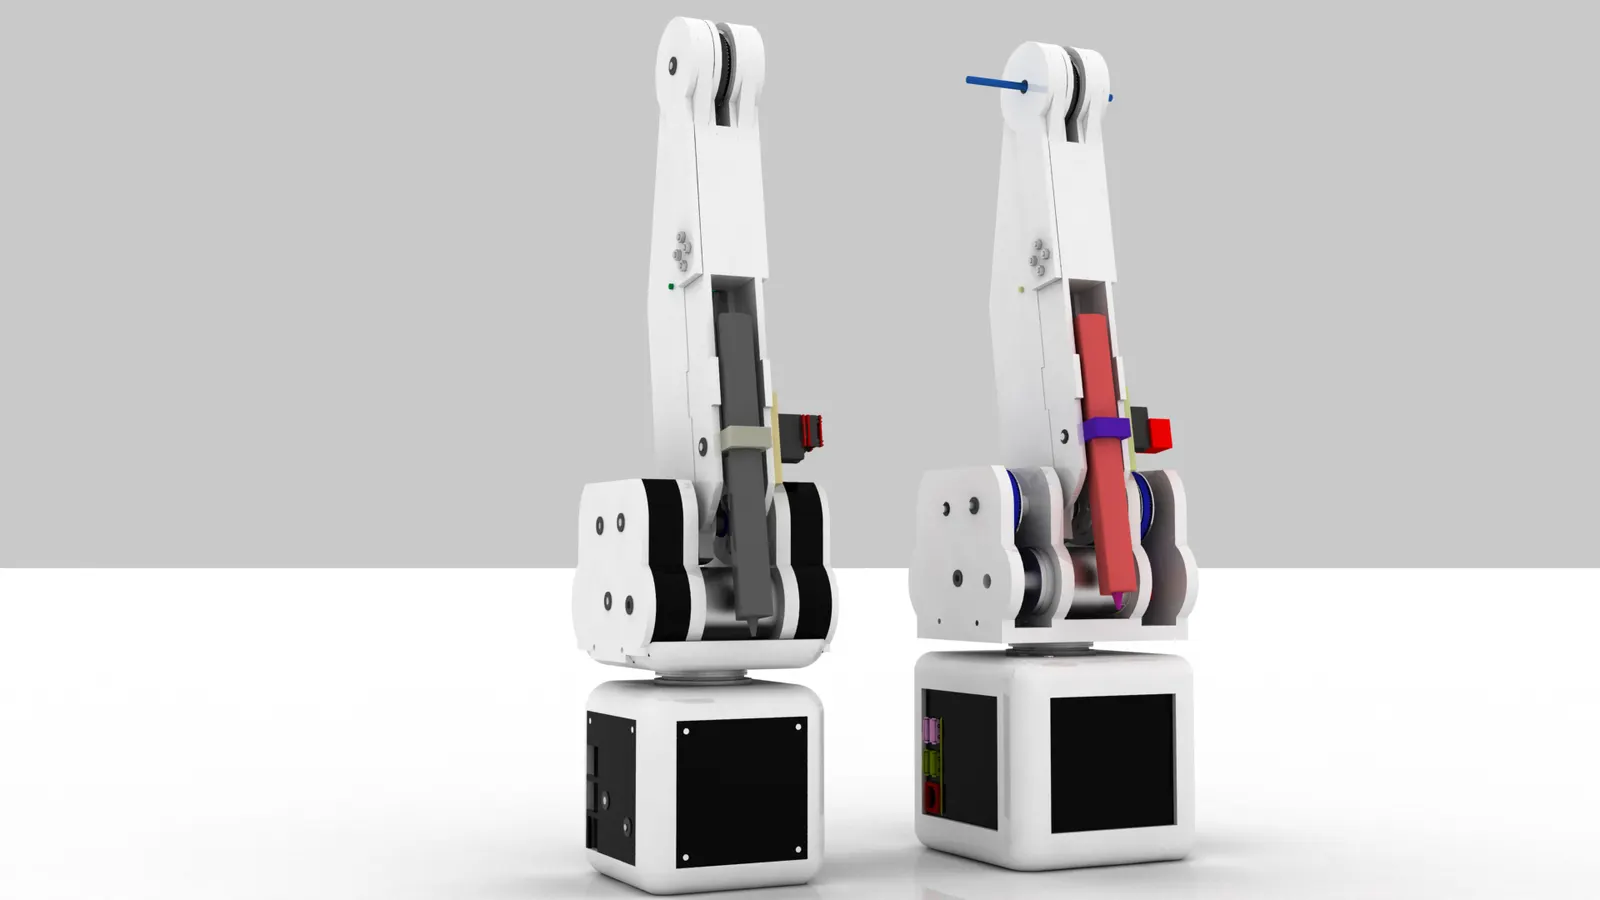 05
Laser-cut wooden arm, fourth iteration.
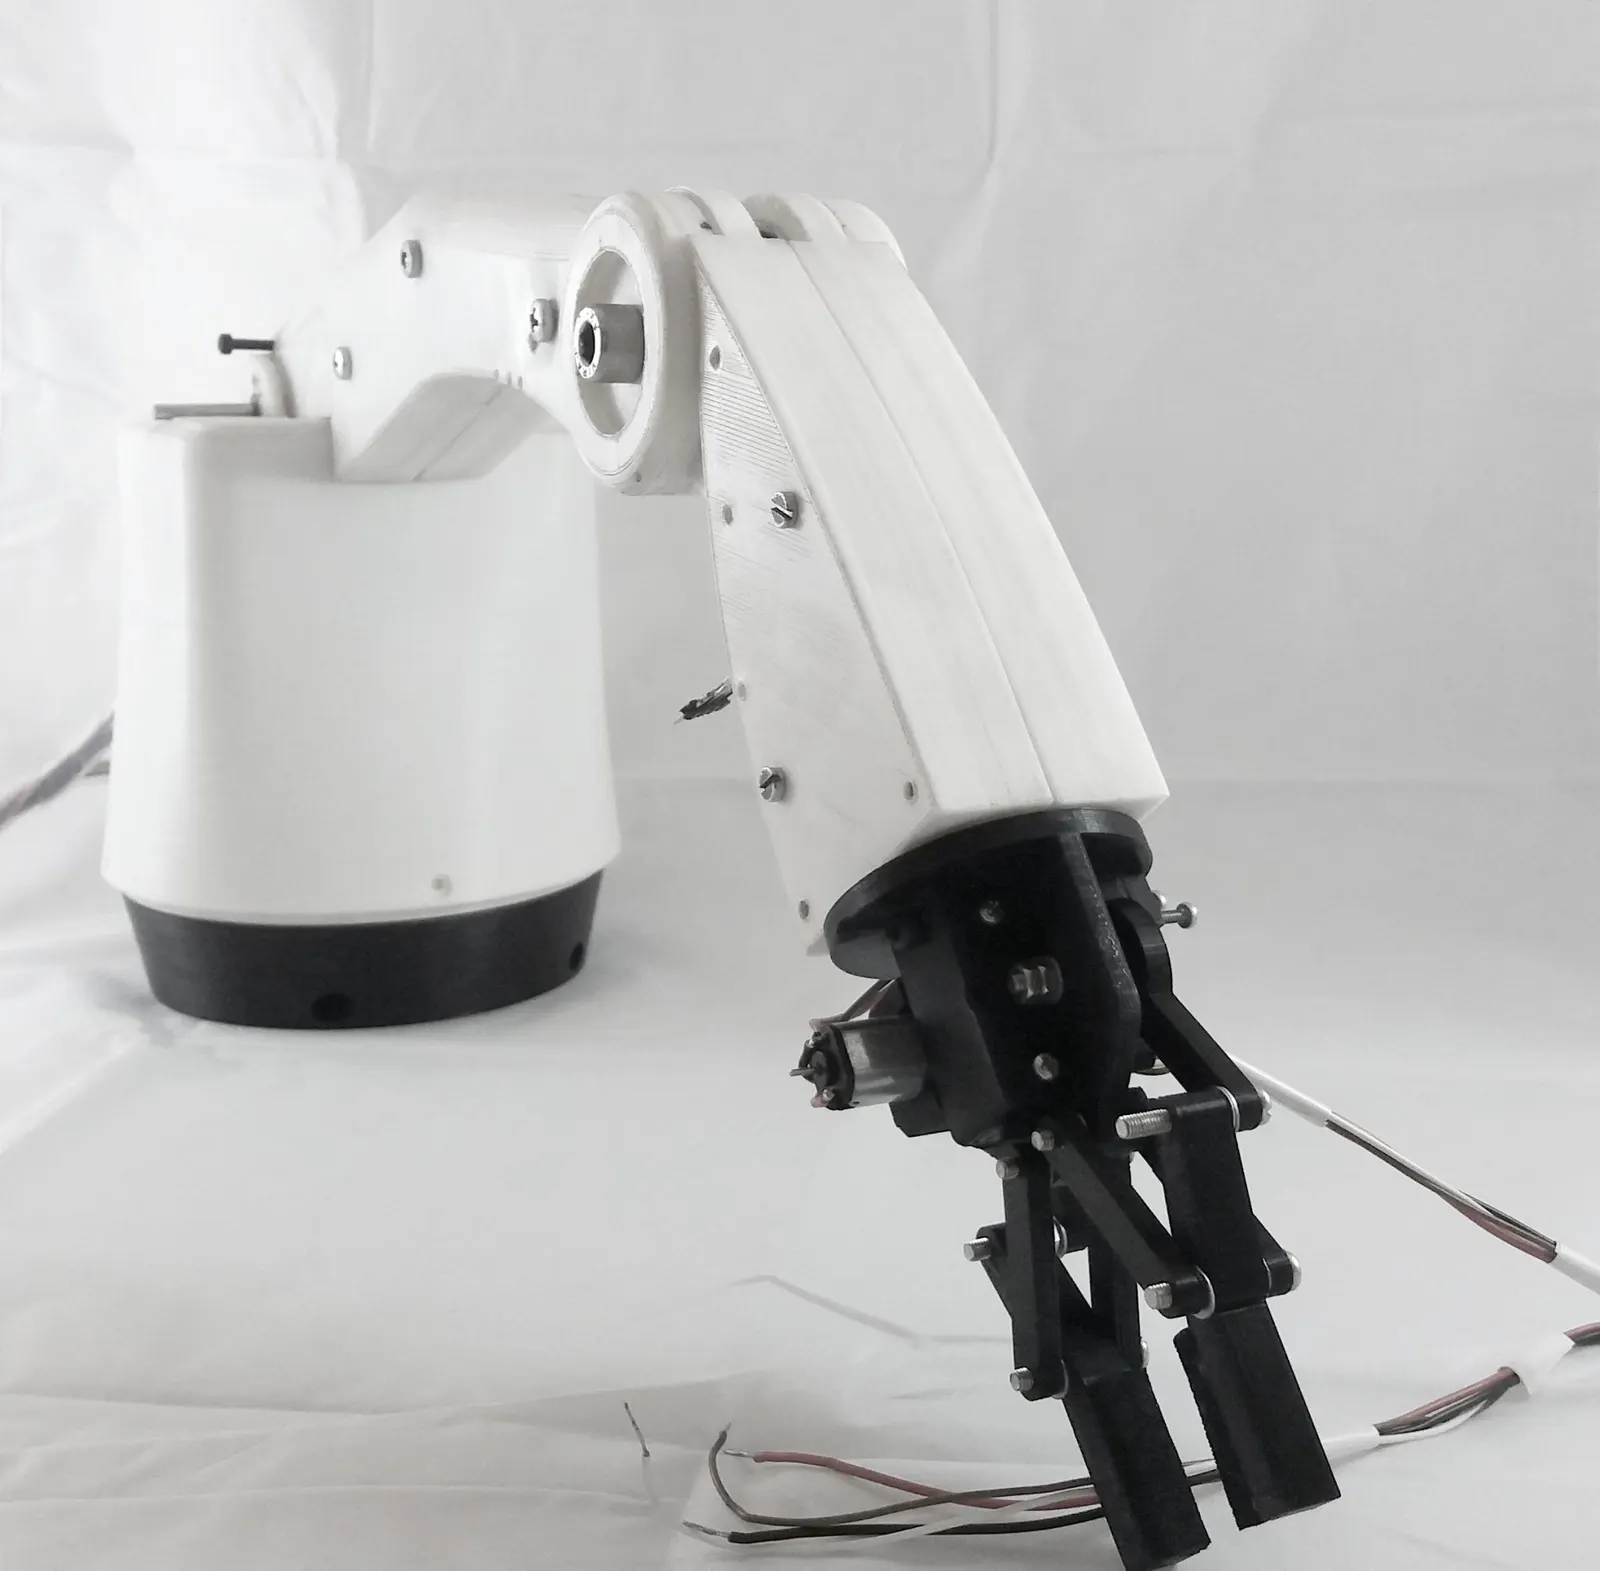 06
White arm with gripper; the largest photo set of the project.
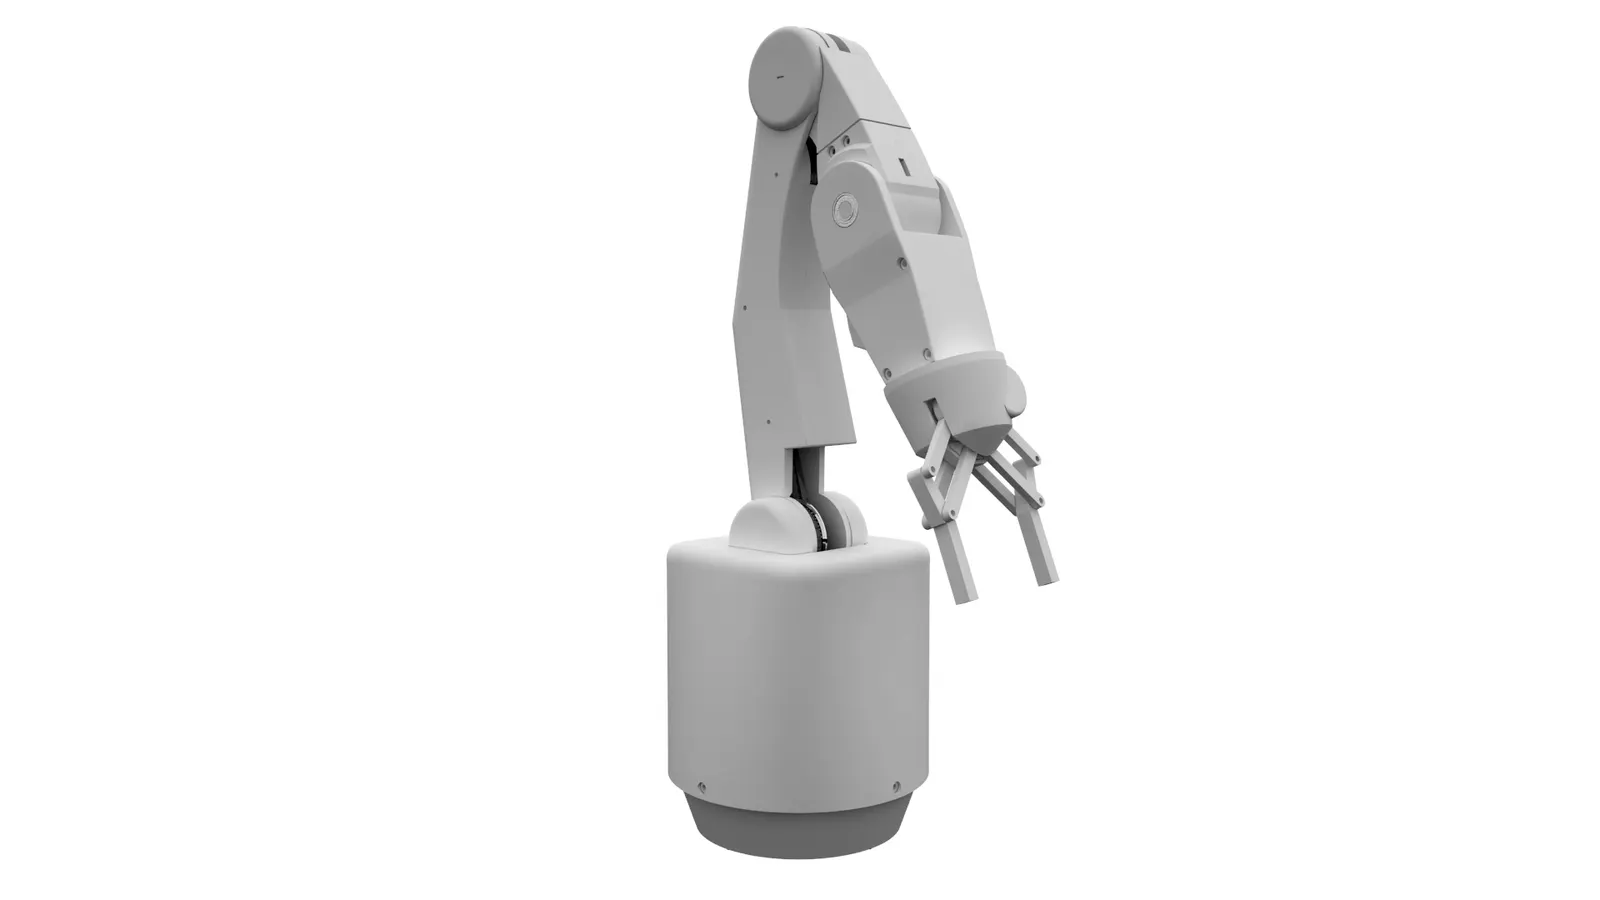 07
HUMERUS-TUCAN, finalist at the European Robotics Forum 2017 entrepreneurship awards, Edinburgh.
HUM[erus]
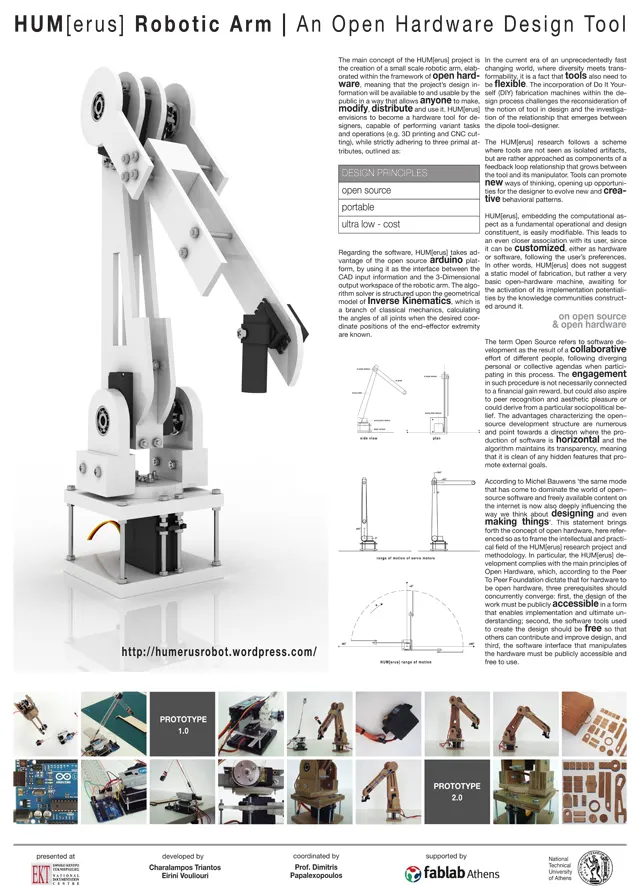
A personal, digital fabrication tool. It is a low-cost, portable robotic arm, with changing head tools, capable of performing basic digitally supported processes, such as 3d printing, drawing and gripping. HUM[erus] is conceived as a user-friendly device, which can be easily assembled, serving as a personal tool for architects and designers, who will be able of using it in their everyday studying and professional design activities.
The project is currently being developed by TRIANTOS Architecture and engined by Zeroone Ltd. It is also supported by the National Technical University of Athens, School of Architecture and Fab Lab Athens. Coordination: Prof. Dimitris Papalexopoulos, Architect NTUA. Advisor: Innovation and Entrepreneurship Unit of NTUA.
TRIANTOS Architecture is a creative team, active in the field of architecture and digital fabrication. Its main research project is HUM[erus] robotic arm, a personal digital fabrication tool, which has been conceived in the perspective of ‘hacking’ and ‘opening’ the scientific knowledge that now accommodates in heavy industry artifacts. Besides HUM[erus], the team’s activities expand into the field of parametric and interaction design. TRIANTOS Architecture collaborates with ZEROONE Ltd. and other external partners. The TRIANTOS Architecture team consists of multi educational engineers and robotics enthusiasts.
Charalampos Triantos is an Architectural Engineer (NTUAthens), also holding an MSc in DesignSpaceCulture (NTUAthens). Currently, he is a PhD candidate in the NTUAthens School of Architecture, researching on the potential use of open source platforms and DIY (Do-It-Yourself) hardware in architectural design and digital fabrication. He is an expert in the collective, crowdsourcing platforms and the implementation of Do It Yourself hardware into the architectural design and construction. Charalampos is the CEO and co-founder of TRIANTOS Architecture and responsible for HUM[erus] R&D, as he is demonstrating prominent skills in mechanical thinking and problem solving. Between 2013-2015 he was employed as a teaching assistant in the NTUAthens School of Architecture, exploring the fields of architectural technology in mass-customization and digital fabrication. He has participated in international and domestic conferences, presenting TRIANTOS Architecture main principle on the theory of hacking, opening up and sharing the scientific knowledge that now accommodates in heavy industry artifacts. Having both professional and research background in the domain of digital fabrication, Charalampos acknowledges that heavy industry machines are complicated to use, big in size and costly. Experiencing the everyday needs of an architect and considering that the tools of design and modeling should follow the global trends, his vision is at bringing the robotic technology to the design activities, promoting it as simple as a design software. Additionally, he practices architecture in Greece, participates in architectural competitions, works as a tutor and consultant for 3D design and animation and has organised interactive workshops in the context of TRIANTOS Architecture.
Nikos Tzamos is passionate about robotics, electronics and computer programming. Awards in computer programming contest like National, Balkan and International Olympiads in Iformatics.
George Margiolos is major in Machine Elements, Award in the European Contest EBEC 2015